Paper Study 3-3
영역 · 자원: Rokey BootCamp (https://www.notion.so/Rokey-BootCamp-1ad39aa2512b803ab013efcd70fb17d9?pvs=21) 고정하기: No 프로젝트: Rokey study 3-3 (https://www.notion.so/Rokey-study-3-3-1bb39aa2512b80148ed0c3594b835956?pvs=21)
KISS-SLAM (2025.03.16)
A Simple, Robust, and Accurate 3D LiDAR SLAM System With Enhanced Generalization Capabilities
KISS : Keep It Small and Simple
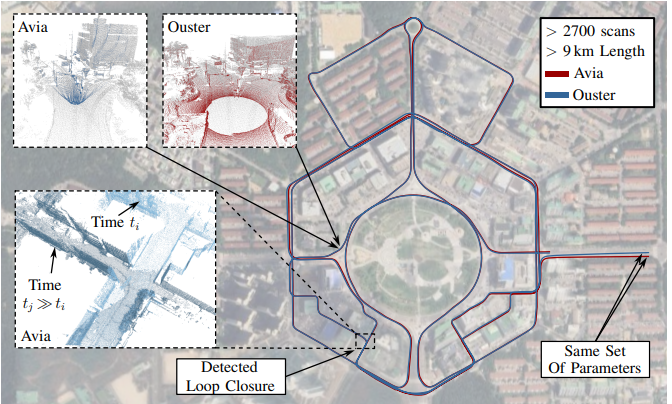
- LiDAR-only SLAM not IMU, GNSS … but high-performing
- pose accuracy
- map
- real world possible
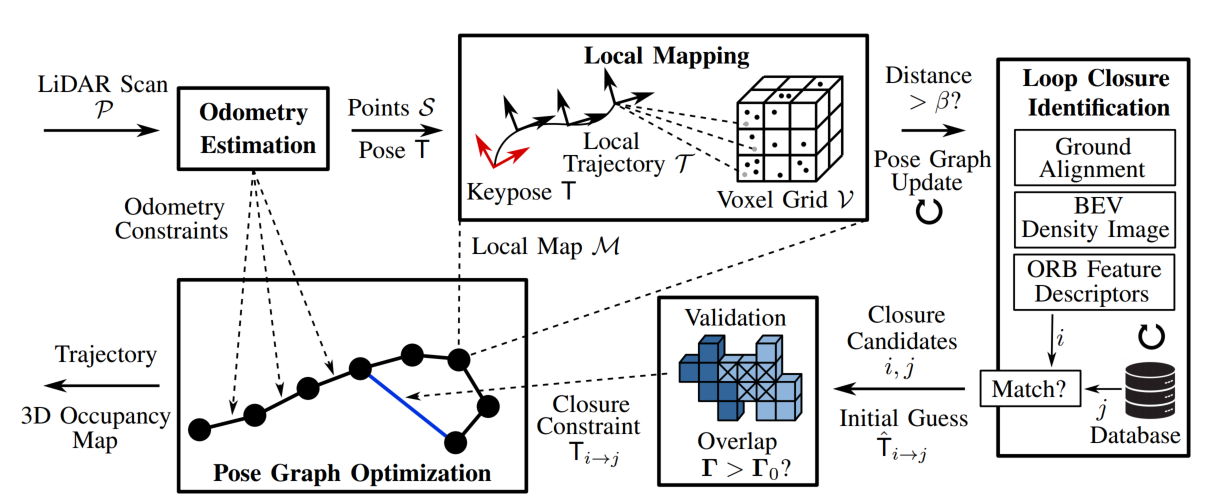
- Graph-based SLAM & LiDAR odometry
- match local maps → optimize the trajectory in a pose graph optimization step
Our Approach to LiDAR-based SLAM
LiDAR Odometry Using KISS_ICP
https://arxiv.org/pdf/2209.15397
- The LiDAR sensor in the odometry frame at time , :
- The incoming point cloud :
- The first pre-process by de-skewing and voxel downsampling :
(https://velog.io/@se0yeon00/PointCloud-를-Voxel-grid-로-다운샘플링-하기)
- The previous estimate of the LiDAR pose :
- A constant velocity motion model prediction :
- An initial guess for the current LiDAR pose :
→ ICP algorithm : point-to-point Iterative Closet Point
(https://alida.tistory.com/105)(https://nbviewer.org/github/niosus/notebooks/blob/master/icp.ipynb#Non-linear-Least-squares-based-ICP)
- The local map points :
- residual : ,
- cost function : ( c : The set of nearest neighbor correspondenecs)
- minimize EQ (least squares fashion) :
Local Mapping and Pose Graph Construction
→ approach avoids main training a single global map through a local map-splitting strategy.
- Local map :
- Keypose :
- local trajectory :
- voxel grid :
→ Create a new local map when the traveled distance exceeds a certain threshold
Loop Closing
https://arxiv.org/pdf/2501.07399
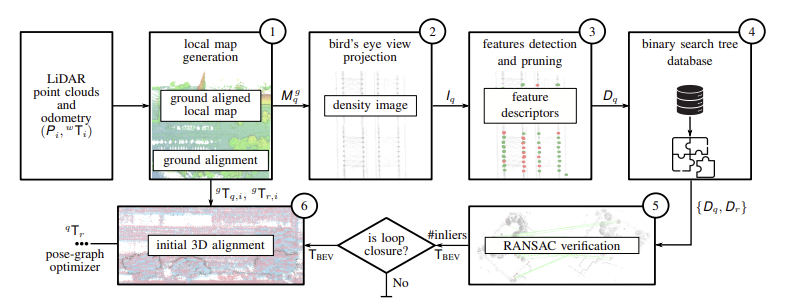
- Ground Alignment → x-y-plane of the keypose reference frame
- BEV Density Image
- ORB Feature Descriptors
- the SzymkiewiczSimson overlap coefficient: → 2D alignment of the density images
- compute mean of the point coordinates and a per-voxel normal vector
- → (resulting point cloud)
- apply the initial guess & perfom a point cloud registration step between the voxel-based point clouds